Skip to content
  • facebook.com
  • twitter.com
  • t.me
  • instagram.com
  • youtube.com
Robotics Engineering

Engineering Intelligence. Creating the Future of Automation.

Subscribe
  • Online Tools
  • Home
  • Robotics Engineering App
  • Home
  • 2026
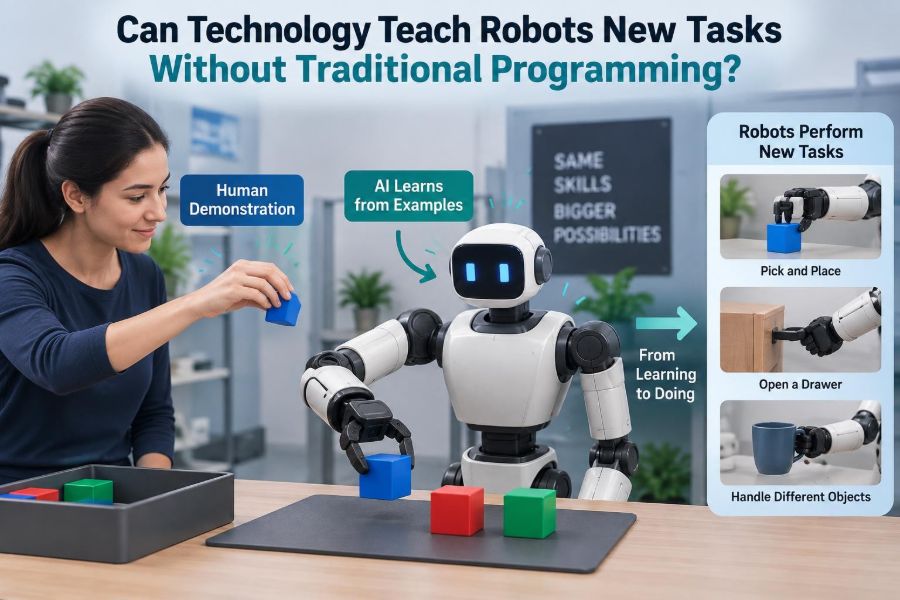
🦾 Can Technology Teach Robots New Tasks Without Traditional Programming?
Posted inFeatured

🦾 Can Technology Teach Robots New Tasks Without Traditional Programming?

Posted by admin October 4, 2026
See how demonstrations, simulation, rewards, and language tools help robots learn—and why safe deployment still needs serious engineering. 🧠⚙️🦾
Read More
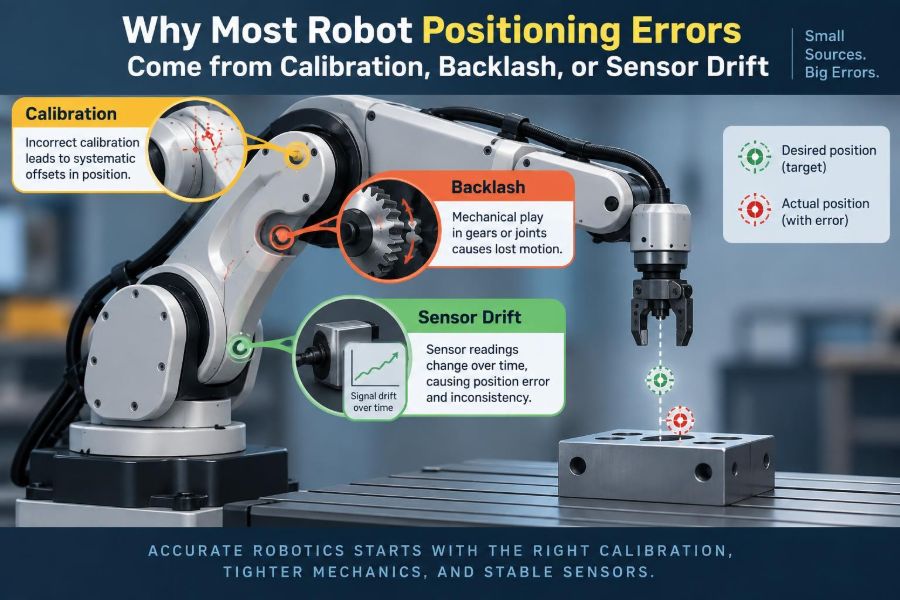
🦾 Why Most Robot Positioning Errors Come from Calibration, Backlash, or Sensor Drift
Posted inFeatured

🦾 Why Most Robot Positioning Errors Come from Calibration, Backlash, or Sensor Drift

Posted by admin October 4, 2026
A robot can follow every command and still place a part incorrectly. Learn to spot calibration faults, mechanical backlash, and sensor drift before they become production problems. 📏🔧🤖
Read More
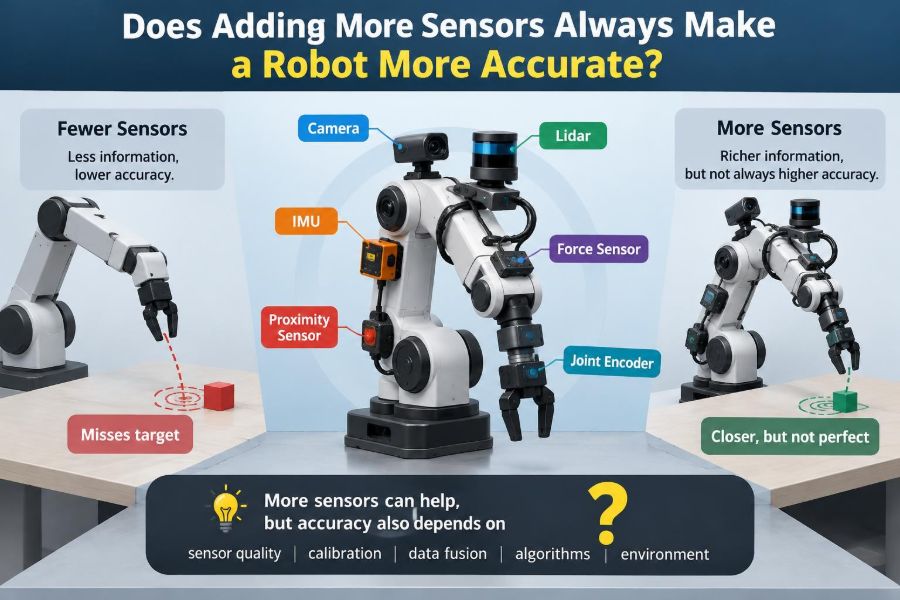
🦾 Does Adding More Sensors Always Make a Robot More Accurate?
Posted inFeatured

🦾 Does Adding More Sensors Always Make a Robot More Accurate?

Posted by admin October 3, 2026
A bigger sensor stack can reduce uncertainty—or introduce delay, bias, and conflicting data. Learn what makes sensing genuinely useful in real robots. 📡🧭🤖
Read More
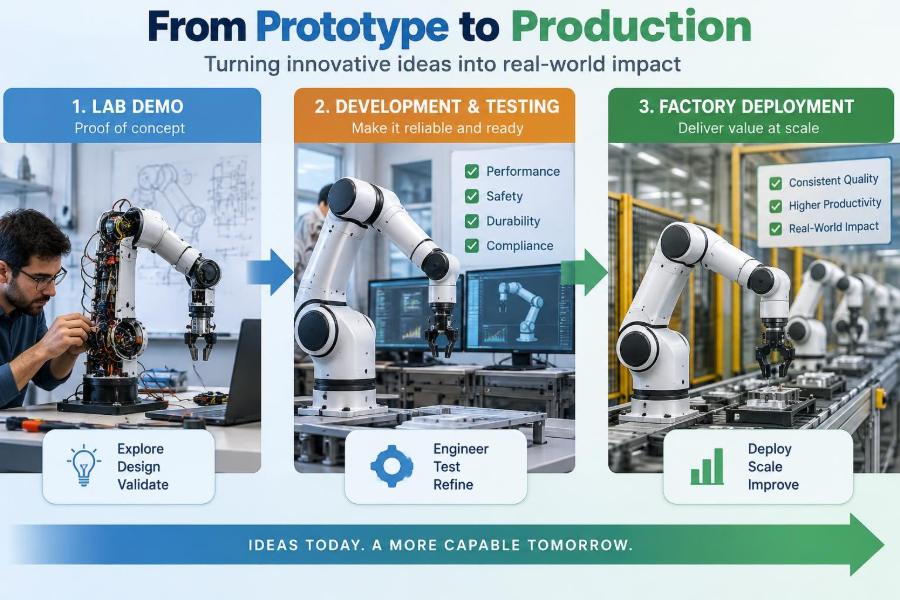
🦾 From Prototype to Production: How a Robot Moves from Lab Demo to Factory Deployment
Posted inFeatured

🦾 From Prototype to Production: How a Robot Moves from Lab Demo to Factory Deployment

Posted by admin October 3, 2026
A lab demo proves potential. Factory deployment demands safe recovery, reliable vision, maintainable software, and real workflow design. See what closes the gap 🏭🔧🤖
Read More
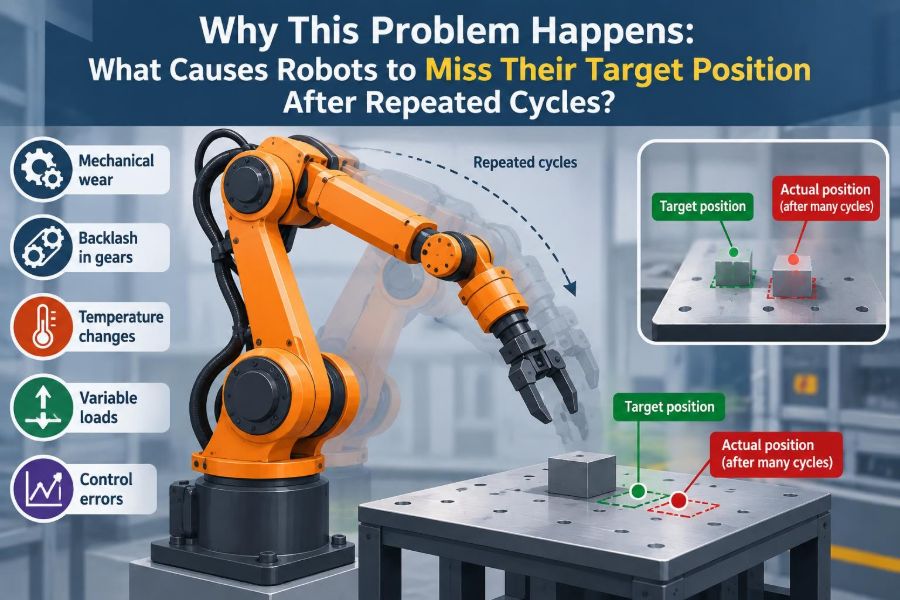
🦾 Why This Problem Happens: What Causes Robots to Miss Their Target Position After Repeated Cycles?
Posted inFeatured

🦾 Why This Problem Happens: What Causes Robots to Miss Their Target Position After Repeated Cycles?

Posted by admin October 2, 2026
A robot can follow its program perfectly and still miss the real target. Learn to spot frames, backlash, heat, payload, vision, and timing faults before they become downtime. 📍🔧👁️
Read More
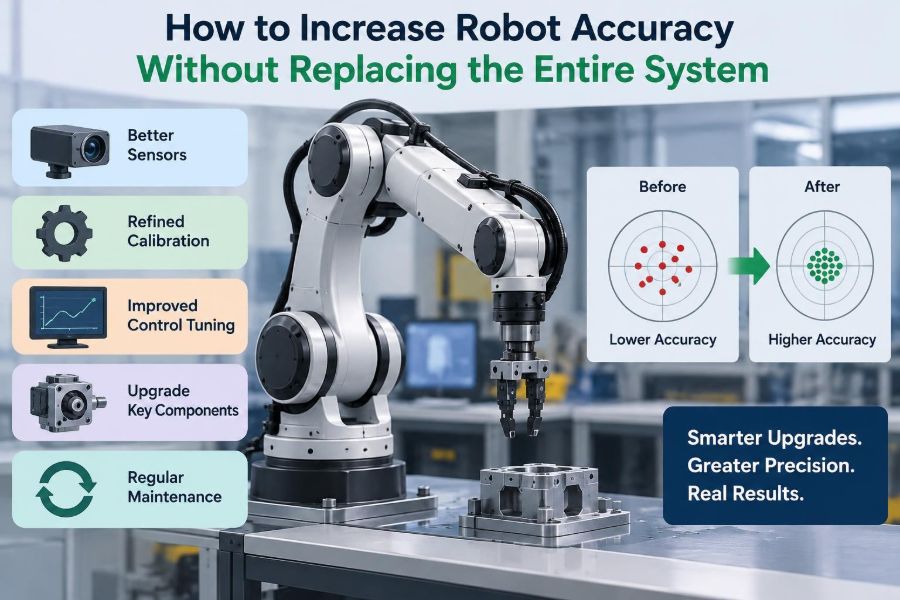
🦾 How to Increase Robot Accuracy Without Replacing the Entire System
Posted inFeatured

🦾 How to Increase Robot Accuracy Without Replacing the Entire System

Posted by admin October 2, 2026
Small misses do not always mean you need a new robot. Learn how to trace errors through tooling, frames, fixtures, sensing, and motion—then fix what matters most. 📐🔧🤖
Read More
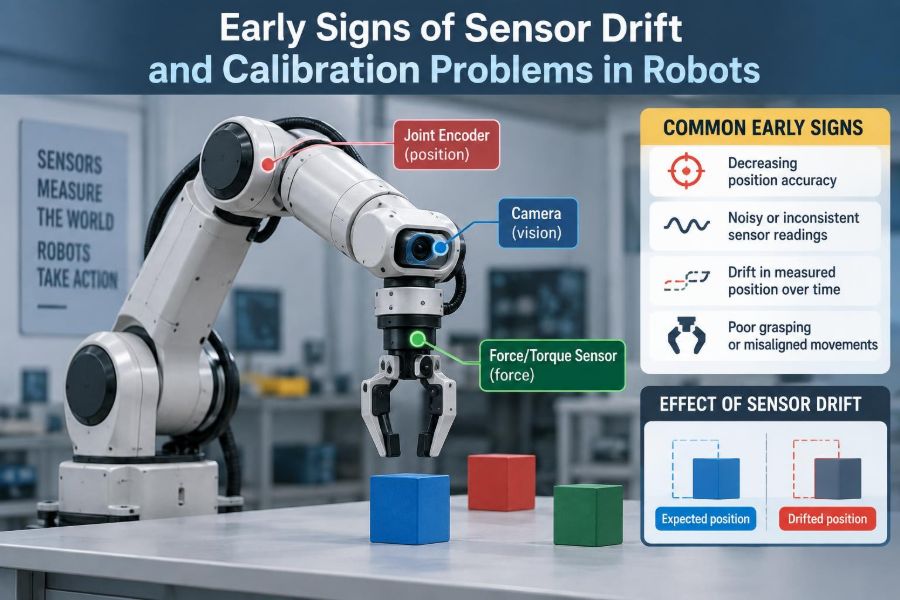
🦾 Early Signs of Sensor Drift and Calibration Problems in Robots
Posted inFeatured

🦾 Early Signs of Sensor Drift and Calibration Problems in Robots

Posted by admin October 1, 2026
Small docking misses, curved paths, and unstable vision can reveal sensor trouble early. Learn what drift looks like, what causes it, and how to test it properly. 📐🤖🧰
Read More
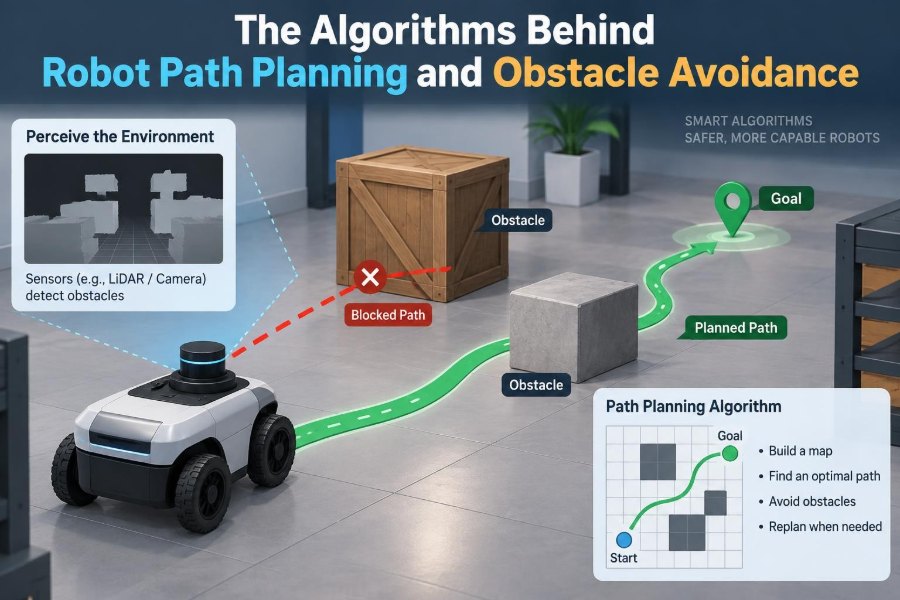
🦾 The Algorithms Behind Robot Path Planning and Obstacle Avoidance
Posted inFeatured

🦾 The Algorithms Behind Robot Path Planning and Obstacle Avoidance

Posted by admin October 1, 2026
From A* search to RRTs, costmaps, and predictive control, see how robots plan workable routes and respond when people or obstacles change the scene. 🤖🚧⚙️
Read More
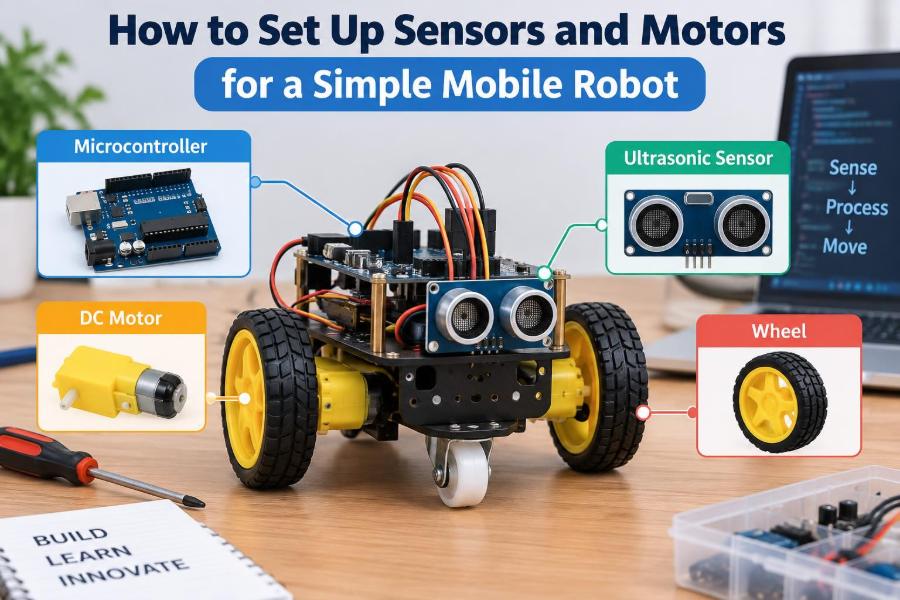
🦾 How to Set Up Sensors and Motors for a Simple Mobile Robot
Posted inFeatured

🦾 How to Set Up Sensors and Motors for a Simple Mobile Robot

Posted by admin September 30, 2026
Build a mobile robot that senses, moves, and stops reliably. Learn motor-driver wiring, sensor placement, shared grounds, PWM, testing, and safer debugging. 🤖🔧⚡
Read More
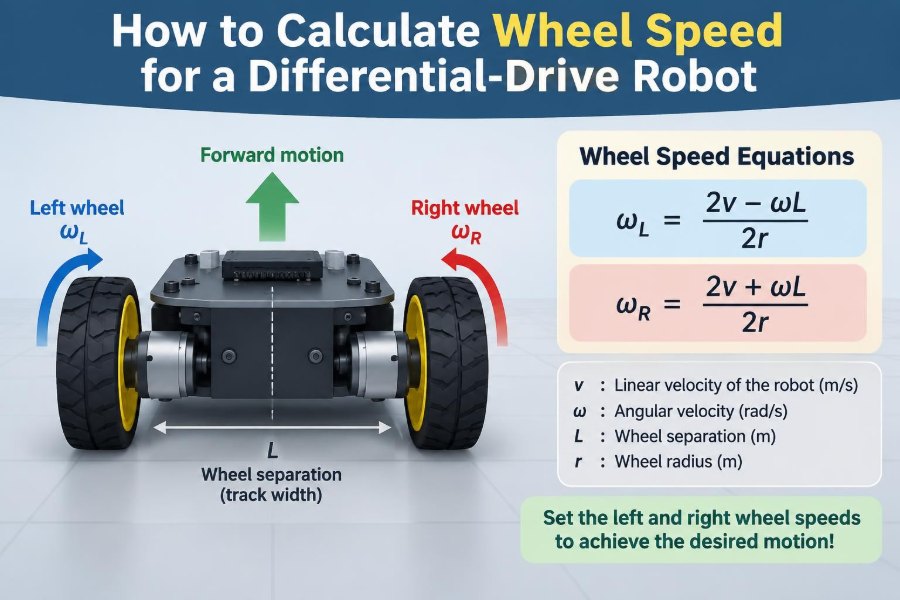
🦾 How to Calculate Wheel Speed for a Differential-Drive Robot
Posted inFeatured

🦾 How to Calculate Wheel Speed for a Differential-Drive Robot

Posted by admin September 30, 2026
Turn forward speed and rotation commands into accurate left and right wheel targets. Learn the equations, RPM conversion, calibration checks, and real-world limits. ⚙️🧭🤖
Read More

Posts pagination

1 2 3 … 6 Next page

Recent Posts

  • 🦾 Can Technology Teach Robots New Tasks Without Traditional Programming?
  • 🦾 Why Most Robot Positioning Errors Come from Calibration, Backlash, or Sensor Drift
  • 🦾 Does Adding More Sensors Always Make a Robot More Accurate?
  • 🦾 From Prototype to Production: How a Robot Moves from Lab Demo to Factory Deployment
  • 🦾 Why This Problem Happens: What Causes Robots to Miss Their Target Position After Repeated Cycles?

Recent Comments

No comments to show.

Archives

  • October 2026
  • September 2026
  • August 2026
  • March 2025
  • February 2025
  • October 2024
  • January 2022
  • November 2021
  • October 2021
  • August 2021
  • September 2020

Categories

  • Autonomous Vehicles
  • Basics
  • Featured
  • Humanoid Application and Research
  • Kinematics
  • Motion Tracking and Gesture Recognition
  • New Trends in 3D Printing
  • Recent Advances in Robotic Systems
  • Robot Building
  • Robot Programming
  • Robotic Kits
  • Robotic System Application Control and Progress
  • Robotics Operation in Hazardous Environment
  • Search and Rescue Robots
Copyright 2026 — Robotics Engineering. All rights reserved. Bloghash WordPress Theme
Scroll to Top