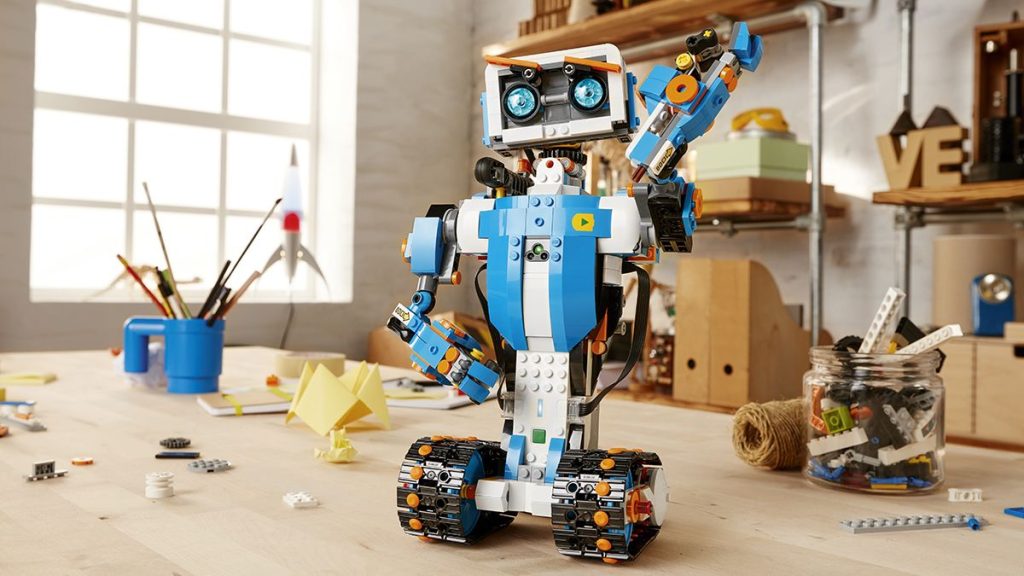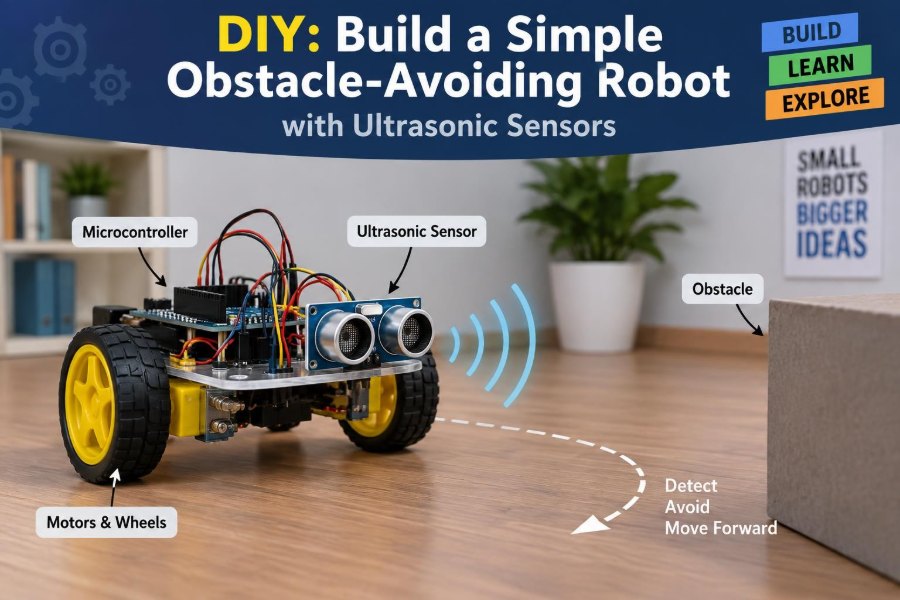
Build a small autonomous rover that senses walls, makes turn decisions, and learns from real sensor limits. Get wiring, code logic, tests, and fixes in one guide. π€π§β‘
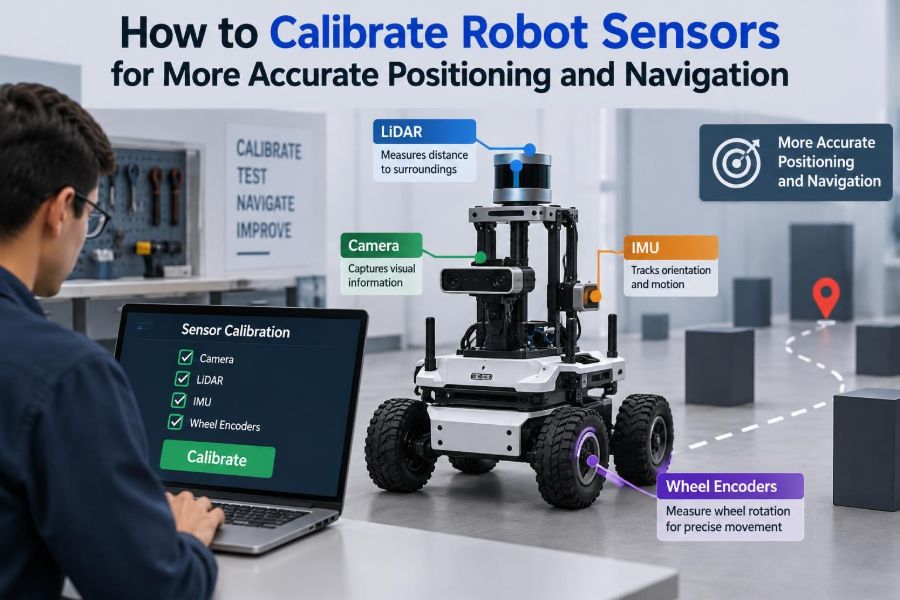
Small errors in wheels, IMUs, cameras, and timestamps can become major navigation misses. Learn a practical calibration workflow that holds up beyond the lab. π·πβοΈ
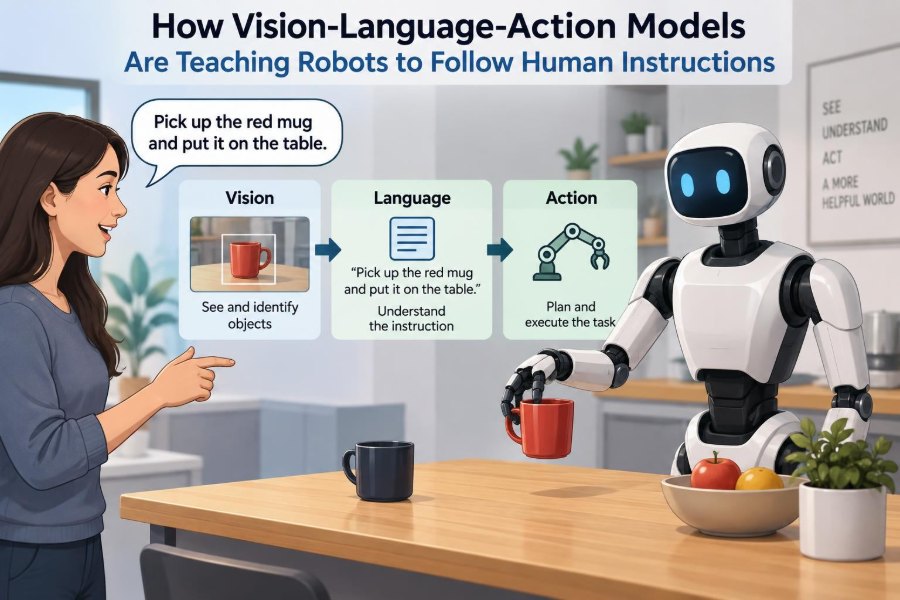
Vision-language-action models connect cameras, human instructions, and robot movement. See how they work, where they fail, and why safety still matters. βοΈπ£οΈπ€
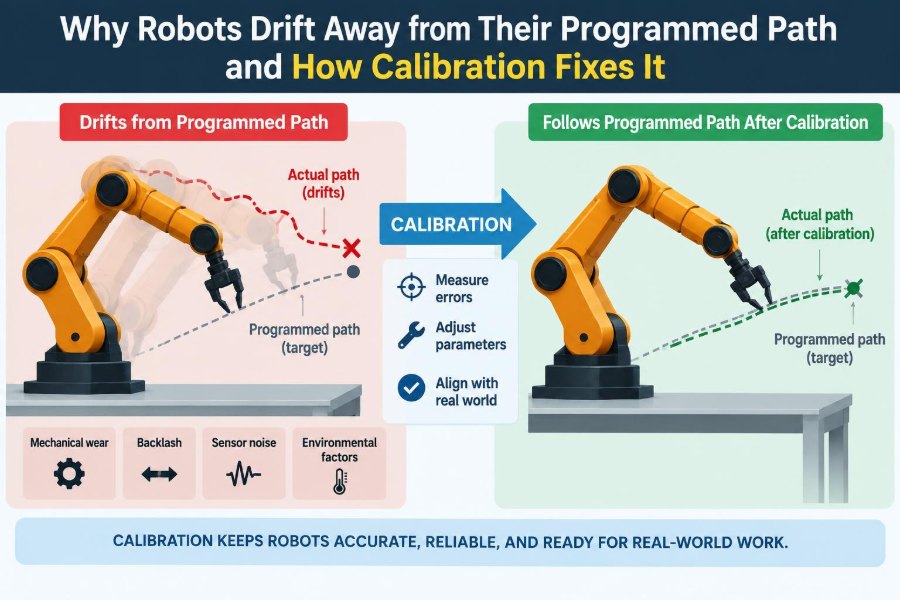
A correct program can still produce wrong motion. Learn how wheels, encoders, frames, tools, and sensors create driftβand how disciplined calibration brings robots back on target. ππ§βοΈ
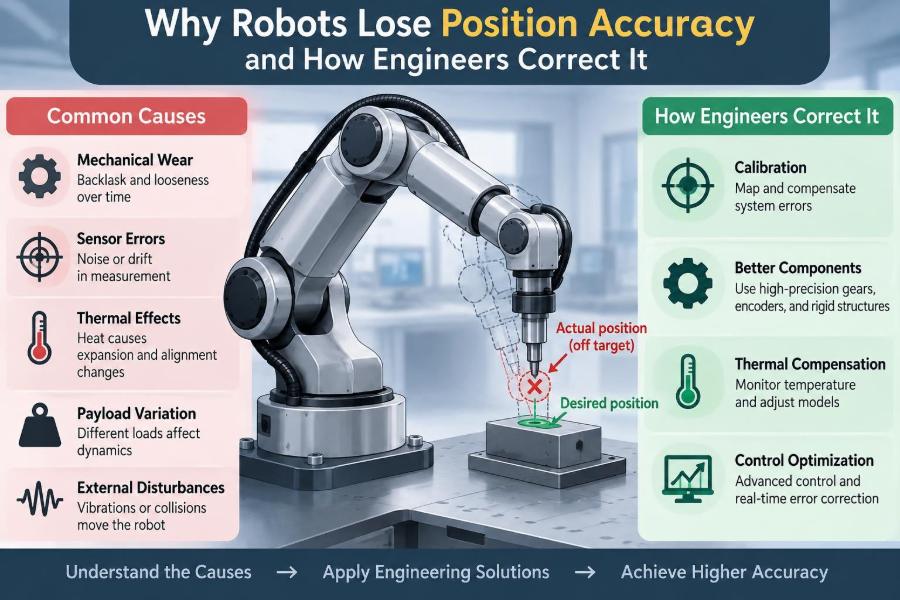
A robot can report the right coordinates and still miss the real target. Learn how backlash, calibration, payloads, heat, and sensors affect precisionβand how engineers diagnose them. πβοΈπ
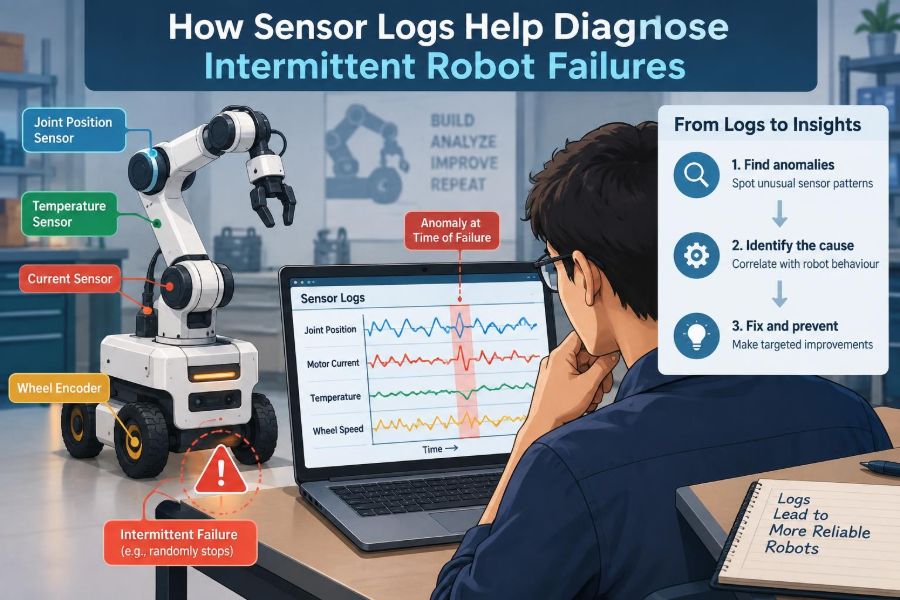
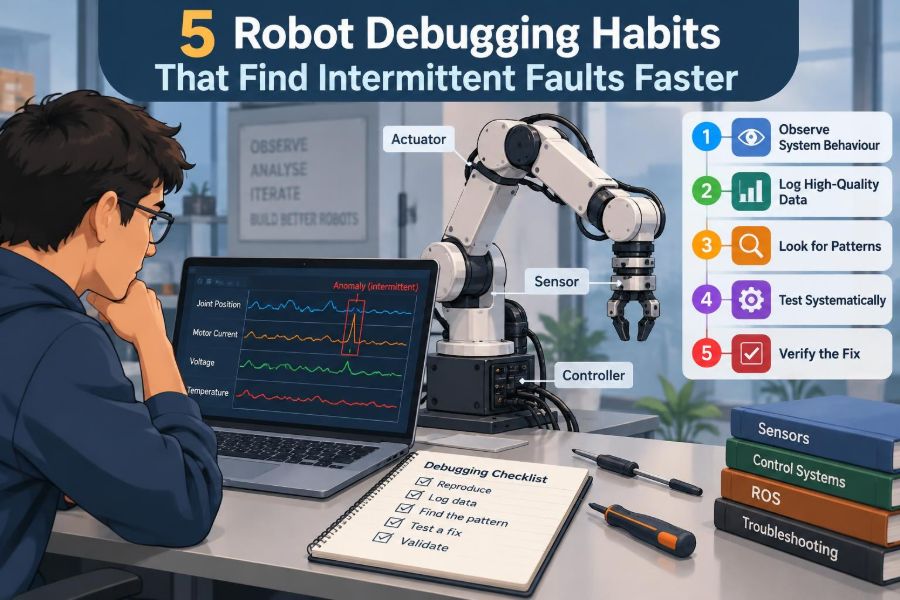
A robot that fails only sometimes leaves clues in timing, confidence, and context. Learn how to capture, compare, and trace sensor logs to the real cause. ππβοΈ
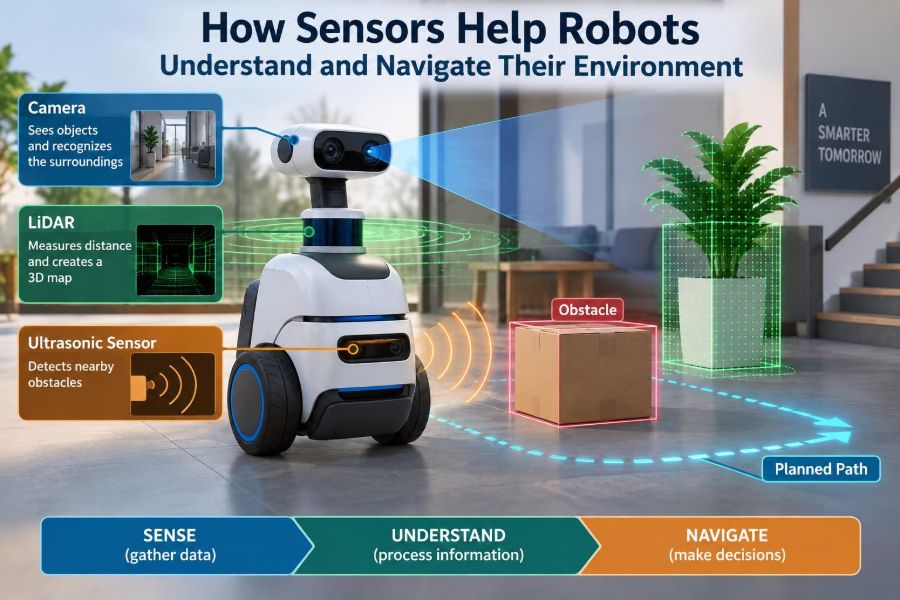
From wheel encoders and cameras to lidar, radar, and touch, discover how robots build maps, avoid obstacles, and navigate despite uncertainty. π€π‘πΊοΈ
Rare robot failures are not random mysteries. Learn five disciplined habits for capturing evidence, isolating triggers, checking timing, and proving a fix holds. π οΈππ
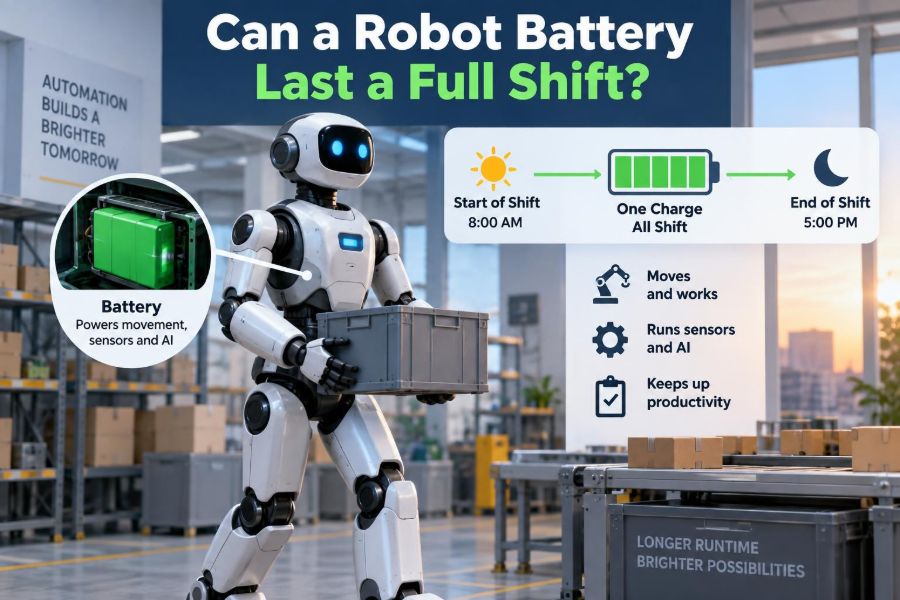
Battery capacity is only the beginning. Learn how payloads, routes, idle power, charging queues, temperature, and safety reserves decide whether a robot stays productive. π€β‘π
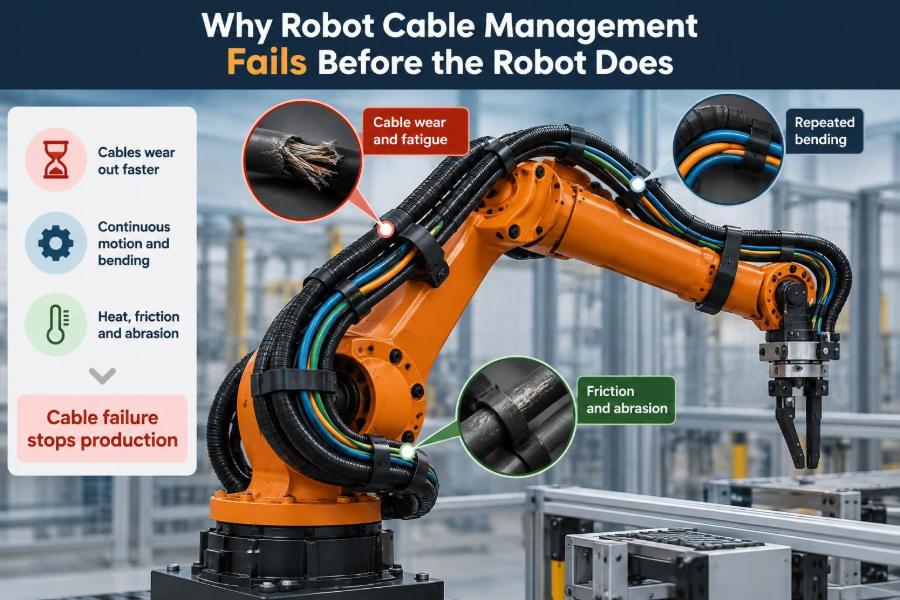
Intermittent faults, damaged wrist cables, and surprise downtime often share one cause: uncontrolled cable motion. Learn what to inspect before a small rub becomes a shutdown. π§β‘π€