Skip to content
  • facebook.com
  • twitter.com
  • t.me
  • instagram.com
  • youtube.com
Robotics Engineering

Engineering Intelligence. Creating the Future of Automation.

Subscribe
  • Online Tools
  • Home
  • Robotics Engineering App
  • Home
  • machine safety
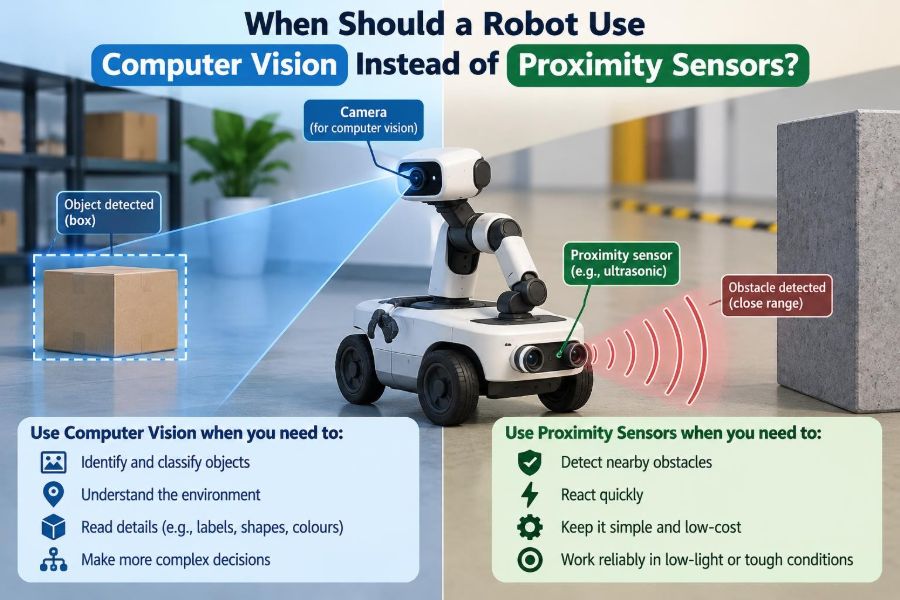
🦾 When Should a Robot Use Computer Vision Instead of Proximity Sensors?
Posted inFeatured

🦾 When Should a Robot Use Computer Vision Instead of Proximity Sensors?

Posted by admin September 25, 2026
A nearby-object signal is not the same as scene understanding. Learn when cameras earn their complexity, where proximity sensors win, and why many robots need both. 🦾📏🔎
Read More

Recent Posts

  • 🦾 How It All Began: From Mechanical Automata to Industrial Robots
  • 🦾 How to Calculate Robot Arm Torque for Different Payloads and Reach Distances
  • 🦾 The Science Behind Robot Balance: How Sensors and Control Systems Keep Robots Upright
  • 🦾 When Should a Robot Use Computer Vision Instead of Proximity Sensors?
  • 🦾 Breakthrough in Robotics: How Vision-Language-Action Models Are Teaching Robots General-Purpose Skills

Recent Comments

No comments to show.

Archives

  • September 2026
  • August 2026
  • March 2025
  • February 2025
  • October 2024
  • January 2022
  • November 2021
  • October 2021
  • August 2021
  • September 2020

Categories

  • Autonomous Vehicles
  • Basics
  • Featured
  • Humanoid Application and Research
  • Kinematics
  • Motion Tracking and Gesture Recognition
  • New Trends in 3D Printing
  • Recent Advances in Robotic Systems
  • Robot Building
  • Robot Programming
  • Robotic Kits
  • Robotic System Application Control and Progress
  • Robotics Operation in Hazardous Environment
  • Search and Rescue Robots
Copyright 2026 — Robotics Engineering. All rights reserved. Bloghash WordPress Theme
Scroll to Top