Skip to content
  • facebook.com
  • twitter.com
  • t.me
  • instagram.com
  • youtube.com
Robotics Engineering

Engineering Intelligence. Creating the Future of Automation.

Subscribe
  • Online Tools
  • Home
  • Robotics Engineering App
  • Home
  • occupancy grids
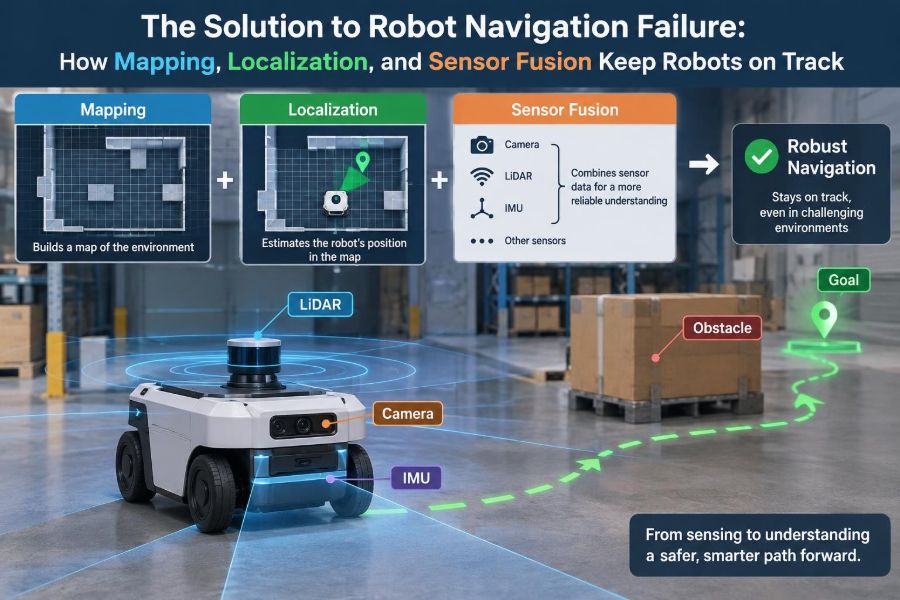
🦾 The Solution to Robot Navigation Failure: How Mapping, Localization, and Sensor Fusion Keep Robots on Track
Posted inFeatured

🦾 The Solution to Robot Navigation Failure: How Mapping, Localization, and Sensor Fusion Keep Robots on Track

Posted by admin November 12, 2026
A robot can have a map and still lose its way. See how localization, lidar, cameras, odometry, and sensor fusion work together to detect drift and recover safely. 📍🗺️⚙️
Read More

Recent Posts

  • 🦾 Understanding Robot End Effectors and How Grippers Determine What a Robot Can Handle
  • 🦾 The Solution to Robot Navigation Failure: How Mapping, Localization, and Sensor Fusion Keep Robots on Track
  • 🦾 Real-World Uses of SLAM in Warehouse Robots, Drones, Autonomous Vehicles, and Inspection Systems
  • 🦾 Breaking Down Robot Movement: Sensors, Controllers, Motors, and Feedback Loops
  • 🦾 What Determines the Price of an Industrial Robot?

Recent Comments

No comments to show.

Archives

  • November 2026
  • October 2026
  • September 2026
  • August 2026
  • March 2025
  • February 2025
  • October 2024
  • January 2022
  • November 2021
  • October 2021
  • August 2021
  • September 2020

Categories

  • Autonomous Vehicles
  • Basics
  • Featured
  • Humanoid Application and Research
  • Kinematics
  • Motion Tracking and Gesture Recognition
  • New Trends in 3D Printing
  • Recent Advances in Robotic Systems
  • Robot Building
  • Robot Programming
  • Robotic Kits
  • Robotic System Application Control and Progress
  • Robotics Operation in Hazardous Environment
  • Search and Rescue Robots
Copyright 2026 — Robotics Engineering. All rights reserved. Bloghash WordPress Theme
Scroll to Top