Skip to content
  • facebook.com
  • twitter.com
  • t.me
  • instagram.com
  • youtube.com
Robotics Engineering

Engineering Intelligence. Creating the Future of Automation.

Subscribe
  • Online Tools
  • Home
  • Robotics Engineering App
  • Home
  • inverse kinematics
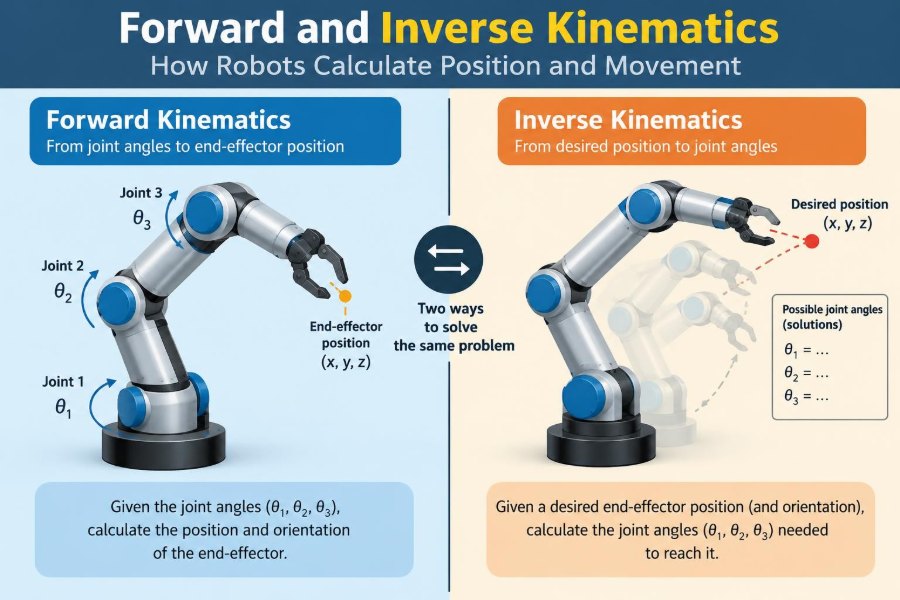
🦾 Explaining Forward and Inverse Kinematics: How Robots Calculate Position and Movement
Posted inFeatured

🦾 Explaining Forward and Inverse Kinematics: How Robots Calculate Position and Movement

Posted by admin November 5, 2026
See how forward and inverse kinematics turn joint angles into precise robot movement—and why frames, singularities, and tool offsets matter. 🤖🧭🛠️
Read More
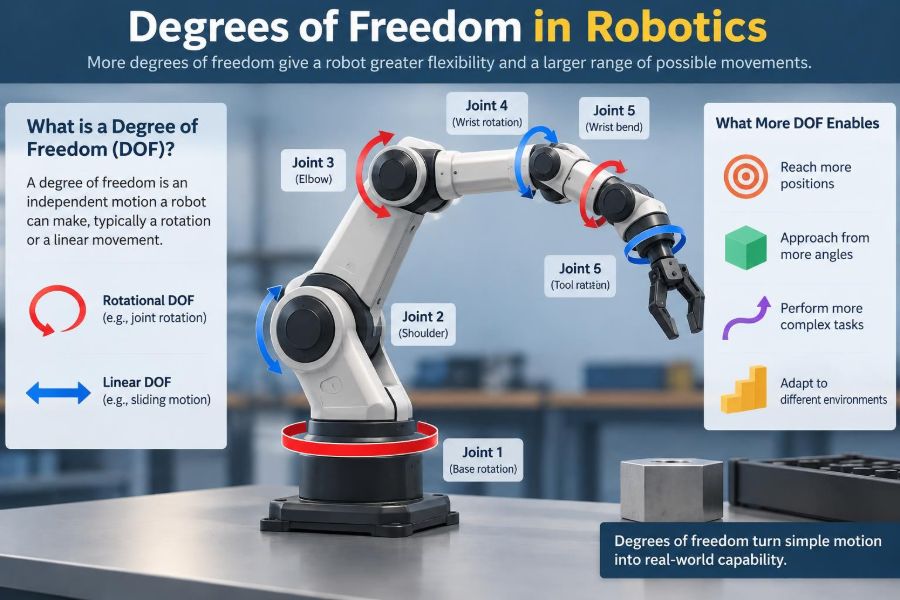
🦾 Understanding Degrees of Freedom and How They Determine What a Robot Can Do
Posted inFeatured

🦾 Understanding Degrees of Freedom and How They Determine What a Robot Can Do

Posted by admin October 13, 2026
A robot’s axis count tells only part of the story. Learn how degrees of freedom shape reach, orientation, dexterity, singularities, and real task capability. 🤖📐🛠️
Read More
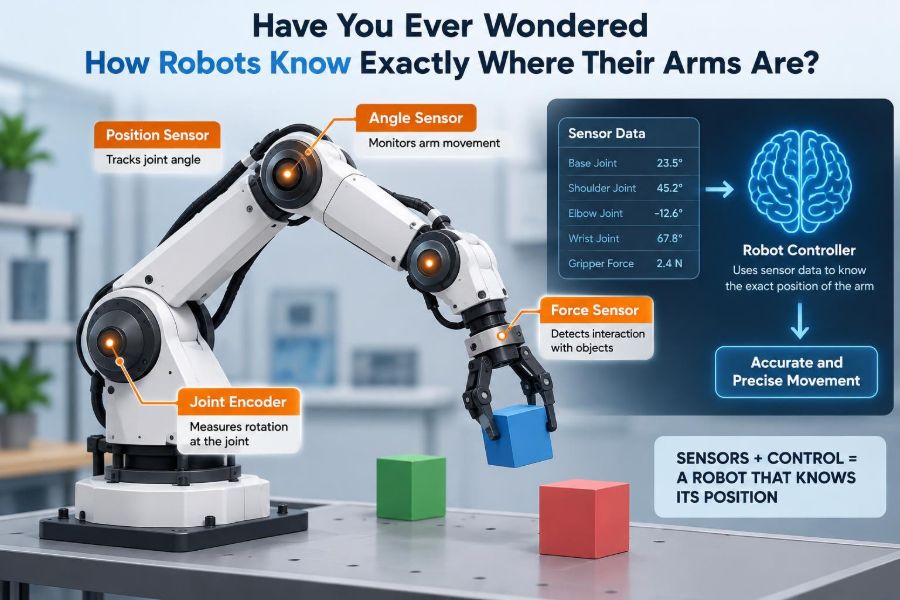
🦾 Have You Ever Wondered How Robots Know Exactly Where Their Arms Are?
Posted inFeatured

🦾 Have You Ever Wondered How Robots Know Exactly Where Their Arms Are?

Posted by admin October 9, 2026
Encoders are only the beginning. See how kinematics, calibration, servo loops, and external sensors help robot arms move accurately in the real world. 🤖📐⚙️
Read More
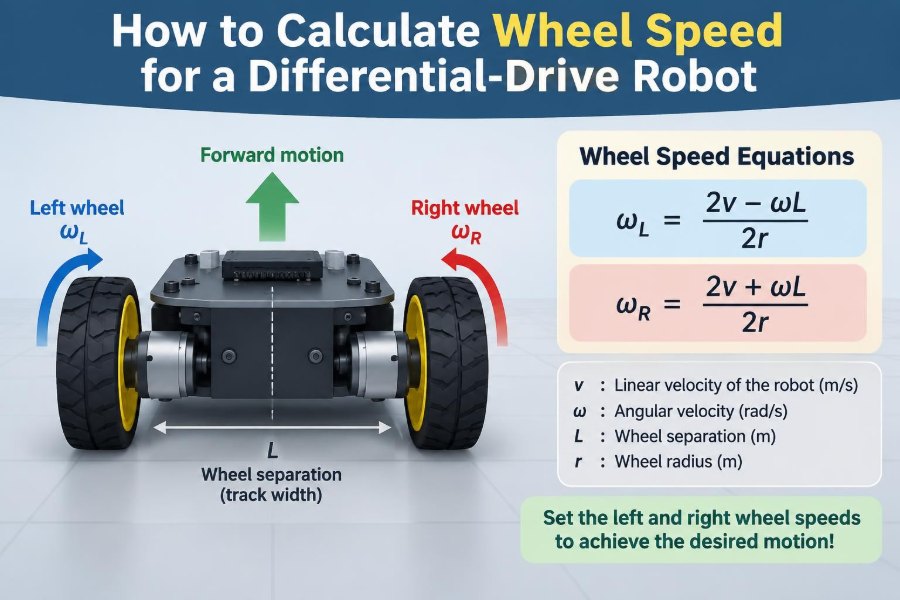
🦾 How to Calculate Wheel Speed for a Differential-Drive Robot
Posted inFeatured

🦾 How to Calculate Wheel Speed for a Differential-Drive Robot

Posted by admin September 30, 2026
Turn forward speed and rotation commands into accurate left and right wheel targets. Learn the equations, RPM conversion, calibration checks, and real-world limits. ⚙️🧭🤖
Read More
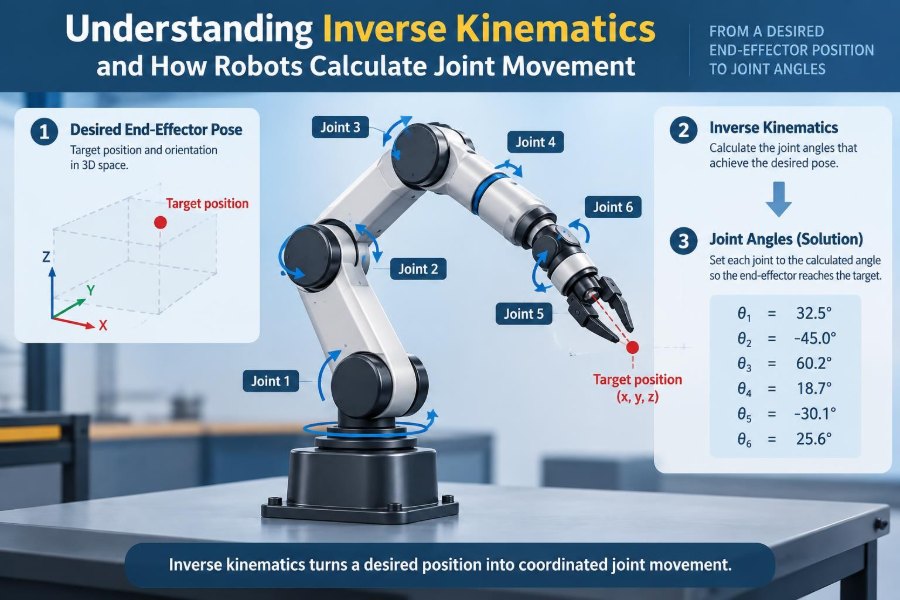
🦾 Understanding Inverse Kinematics and How Robots Calculate Joint Movement
Posted inFeatured

🦾 Understanding Inverse Kinematics and How Robots Calculate Joint Movement

Posted by admin September 28, 2026
A target point is only the beginning. Learn how robots turn position and orientation into safe joint movements—and why singularities, limits, and frames matter. 🤖📐⚙️
Read More
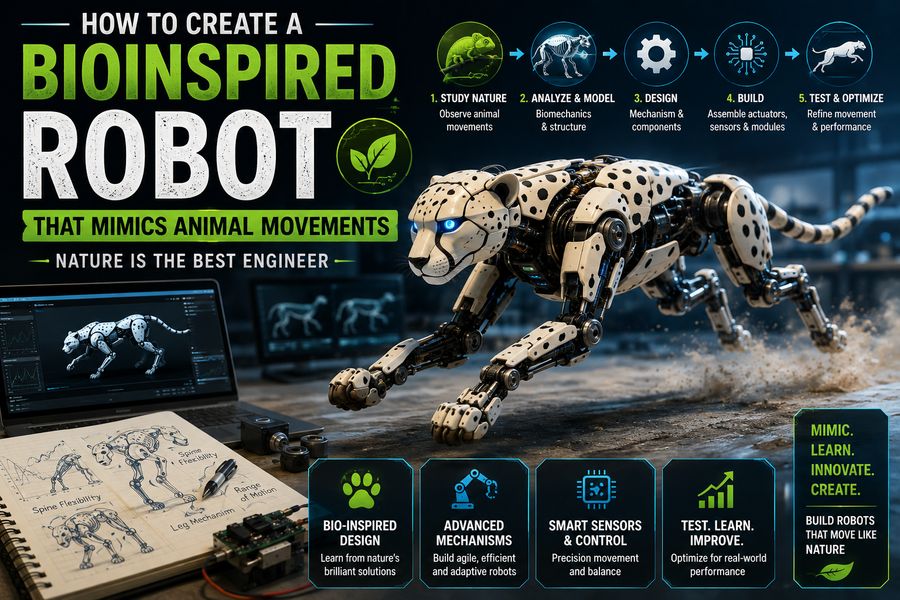
How to Create a Bioinspired Robot That Mimics Animal Movements
Posted inRobot Building Robot Programming Robotics Operation in Hazardous Environment

How to Create a Bioinspired Robot That Mimics Animal Movements

Posted by admin August 14, 2026
Nature has spent millions of years evolving highly efficient ways for animals to walk, crawl,…
Read More

Recent Posts

  • 🦾 Why Is Feedback Control So Important for Precise Robot Movement?
  • 🦾 How Long Can Industrial Robots Operate Before Accuracy and Component Wear Become Noticeable?
  • 🦾 Dealing With Wheel Slip: How Mobile Robots Maintain Accurate Position on Difficult Surfaces
  • 🦾 How to Measure Robot Repeatability and Determine Whether Position Accuracy Is Drifting
  • 🦾 Understanding Robot End Effectors and How Grippers Determine What a Robot Can Handle

Recent Comments

No comments to show.

Archives

  • November 2026
  • October 2026
  • September 2026
  • August 2026
  • March 2025
  • February 2025
  • October 2024
  • January 2022
  • November 2021
  • October 2021
  • August 2021
  • September 2020

Categories

  • Autonomous Vehicles
  • Basics
  • Featured
  • Humanoid Application and Research
  • Kinematics
  • Motion Tracking and Gesture Recognition
  • New Trends in 3D Printing
  • Recent Advances in Robotic Systems
  • Robot Building
  • Robot Programming
  • Robotic Kits
  • Robotic System Application Control and Progress
  • Robotics Operation in Hazardous Environment
  • Search and Rescue Robots
Copyright 2026 — Robotics Engineering. All rights reserved. Bloghash WordPress Theme
Scroll to Top