Skip to content
  • facebook.com
  • twitter.com
  • t.me
  • instagram.com
  • youtube.com
Robotics Engineering

Engineering Intelligence. Creating the Future of Automation.

Subscribe
  • Online Tools
  • Home
  • Robotics Engineering App
  • Home
  • path planning
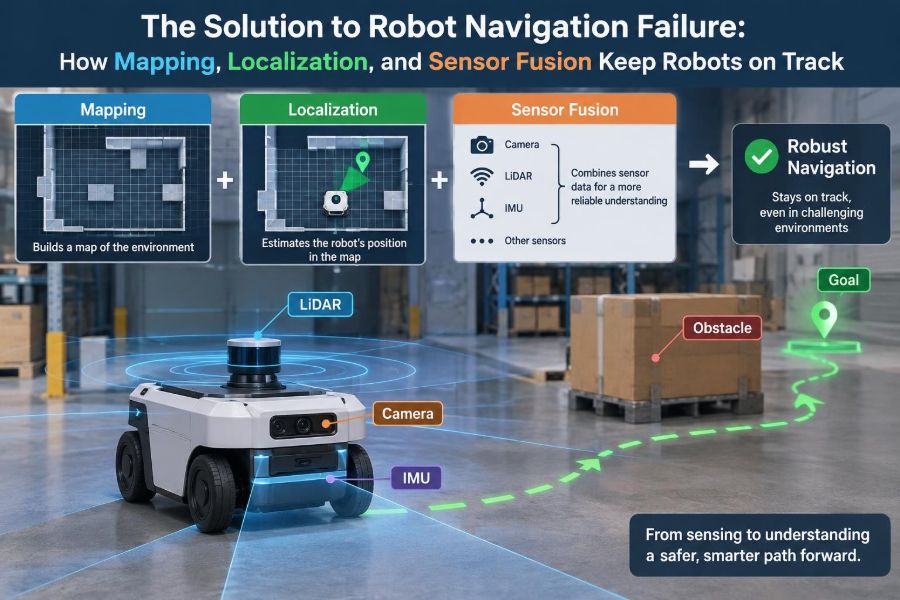
🦾 The Solution to Robot Navigation Failure: How Mapping, Localization, and Sensor Fusion Keep Robots on Track
Posted inFeatured

🦾 The Solution to Robot Navigation Failure: How Mapping, Localization, and Sensor Fusion Keep Robots on Track

Posted by admin November 12, 2026
A robot can have a map and still lose its way. See how localization, lidar, cameras, odometry, and sensor fusion work together to detect drift and recover safely. 📍🗺️⚙️
Read More
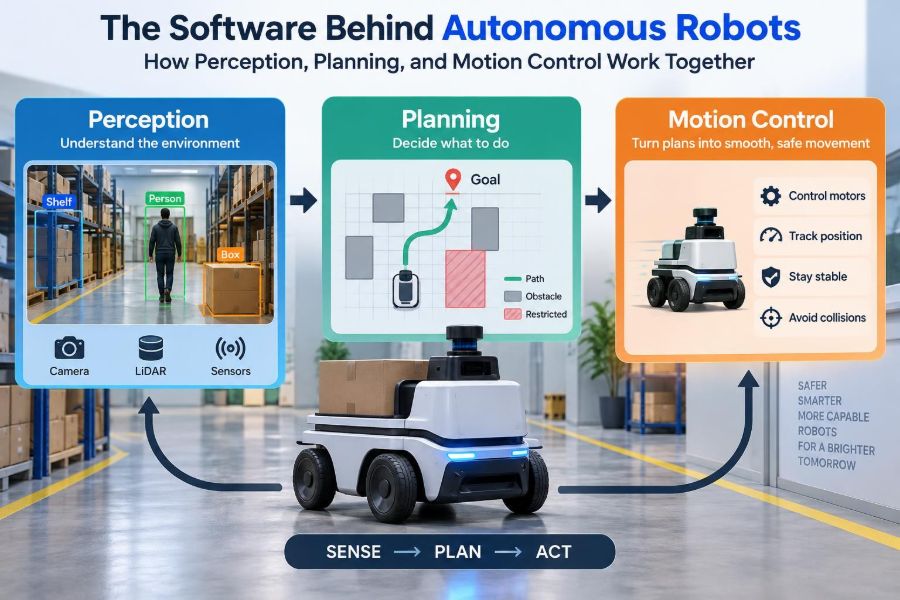
🦾 The Software Behind Autonomous Robots: How Perception, Planning, and Motion Control Work Together
Posted inFeatured

🦾 The Software Behind Autonomous Robots: How Perception, Planning, and Motion Control Work Together

Posted by admin November 9, 2026
Follow the software loop that lets robots sense obstacles, choose routes, and control their motors in real time. Learn where failures happen—and how engineers design for them. 🤖🧭⚙️
Read More
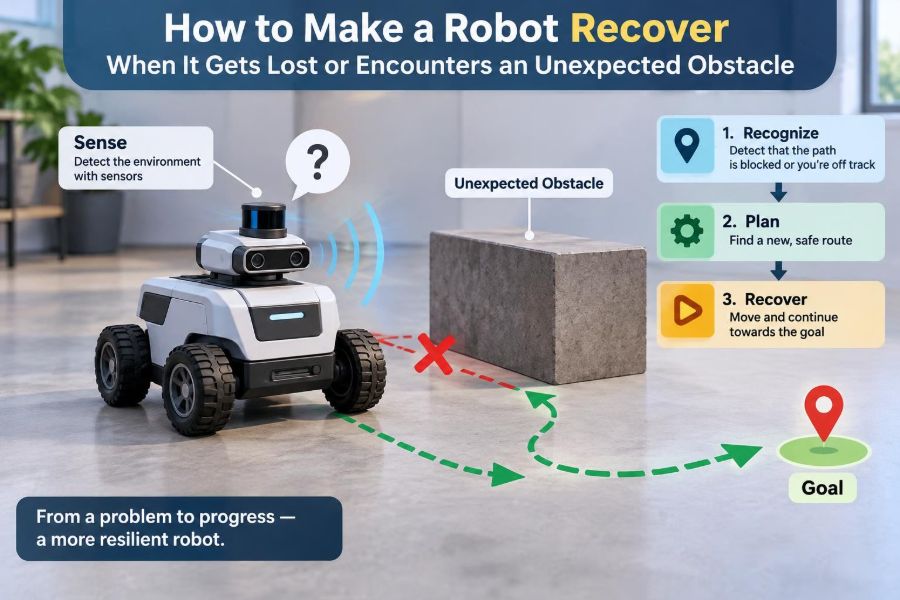
🦾 How to Make a Robot Recover When It Gets Lost or Encounters an Unexpected Obstacle
Posted inFeatured

🦾 How to Make a Robot Recover When It Gets Lost or Encounters an Unexpected Obstacle

Posted by admin November 4, 2026
Unexpected obstacles and lost localization are inevitable. Learn how robots can stop safely, relocalize, replan routes, and know when to ask for help. 🚧🤖⚙️
Read More
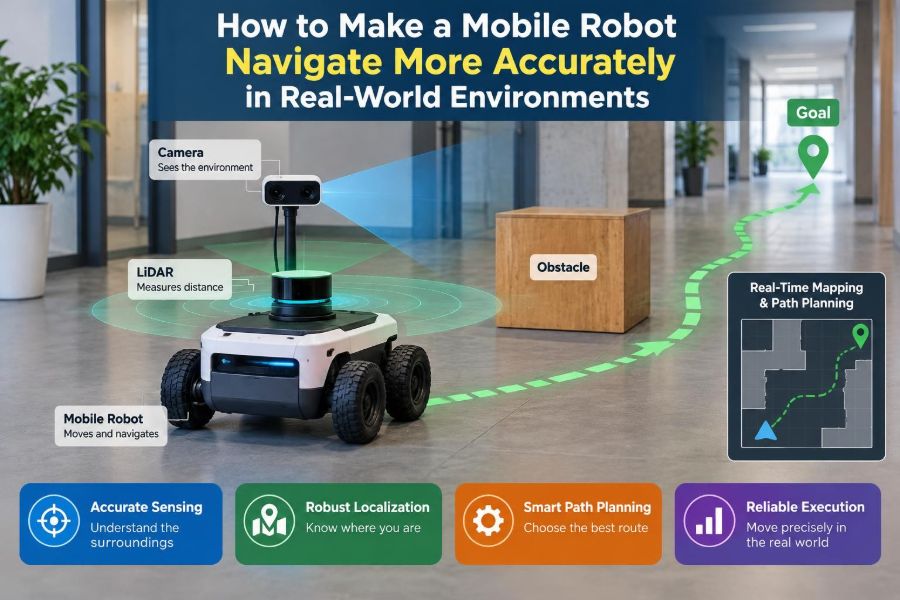
🦾 How to Make a Mobile Robot Navigate More Accurately in Real-World Environments
Posted inFeatured

🦾 How to Make a Mobile Robot Navigate More Accurately in Real-World Environments

Posted by admin October 19, 2026
Wheel slip, bad timestamps, shifting maps, and glare can quietly derail navigation. Learn practical ways to calibrate, fuse sensors, test errors, and recover safely. 🤖📍🛞
Read More
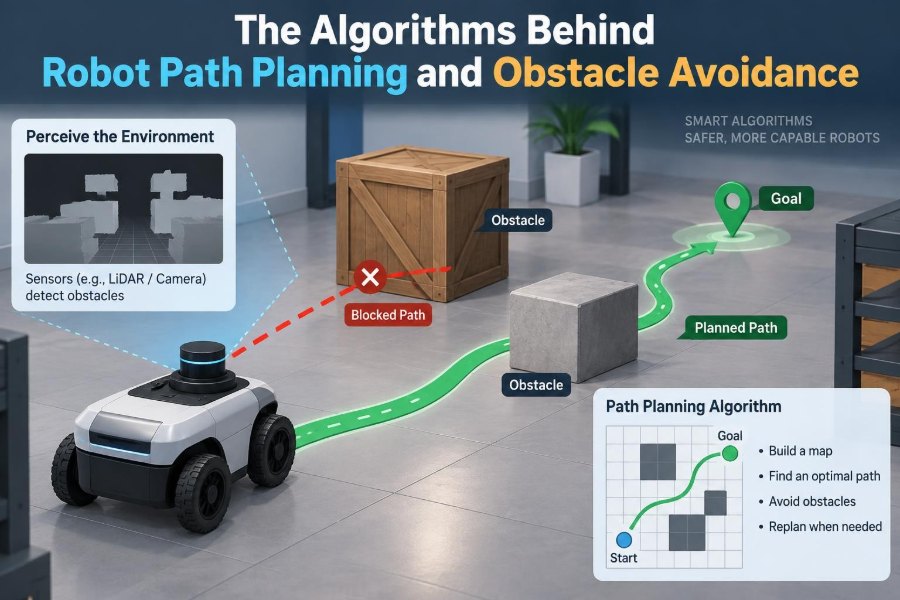
🦾 The Algorithms Behind Robot Path Planning and Obstacle Avoidance
Posted inFeatured

🦾 The Algorithms Behind Robot Path Planning and Obstacle Avoidance

Posted by admin October 1, 2026
From A* search to RRTs, costmaps, and predictive control, see how robots plan workable routes and respond when people or obstacles change the scene. 🤖🚧⚙️
Read More

Recent Posts

  • 🦾 How Long Can Industrial Robots Operate Before Accuracy and Component Wear Become Noticeable?
  • 🦾 Dealing With Wheel Slip: How Mobile Robots Maintain Accurate Position on Difficult Surfaces
  • 🦾 How to Measure Robot Repeatability and Determine Whether Position Accuracy Is Drifting
  • 🦾 Understanding Robot End Effectors and How Grippers Determine What a Robot Can Handle
  • 🦾 The Solution to Robot Navigation Failure: How Mapping, Localization, and Sensor Fusion Keep Robots on Track

Recent Comments

No comments to show.

Archives

  • November 2026
  • October 2026
  • September 2026
  • August 2026
  • March 2025
  • February 2025
  • October 2024
  • January 2022
  • November 2021
  • October 2021
  • August 2021
  • September 2020

Categories

  • Autonomous Vehicles
  • Basics
  • Featured
  • Humanoid Application and Research
  • Kinematics
  • Motion Tracking and Gesture Recognition
  • New Trends in 3D Printing
  • Recent Advances in Robotic Systems
  • Robot Building
  • Robot Programming
  • Robotic Kits
  • Robotic System Application Control and Progress
  • Robotics Operation in Hazardous Environment
  • Search and Rescue Robots
Copyright 2026 — Robotics Engineering. All rights reserved. Bloghash WordPress Theme
Scroll to Top