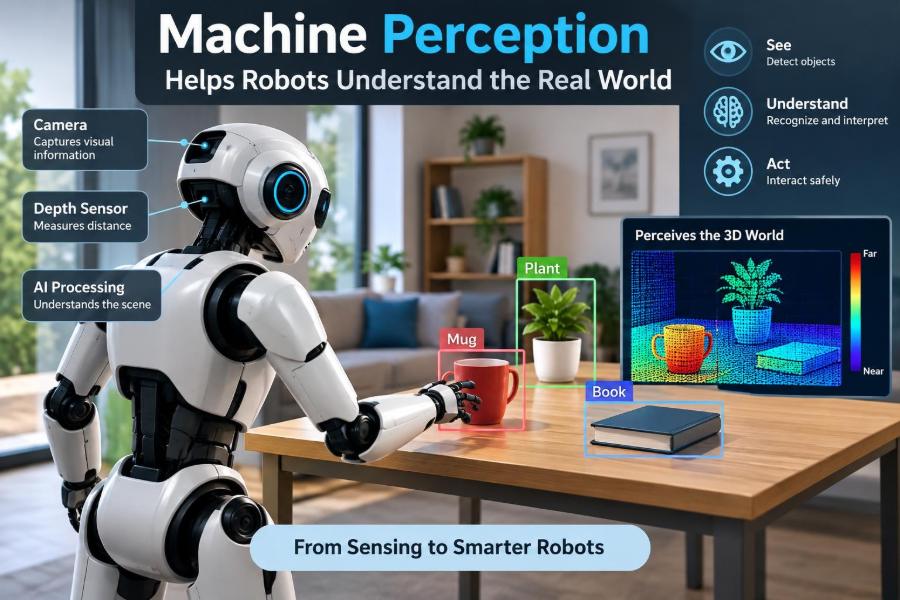
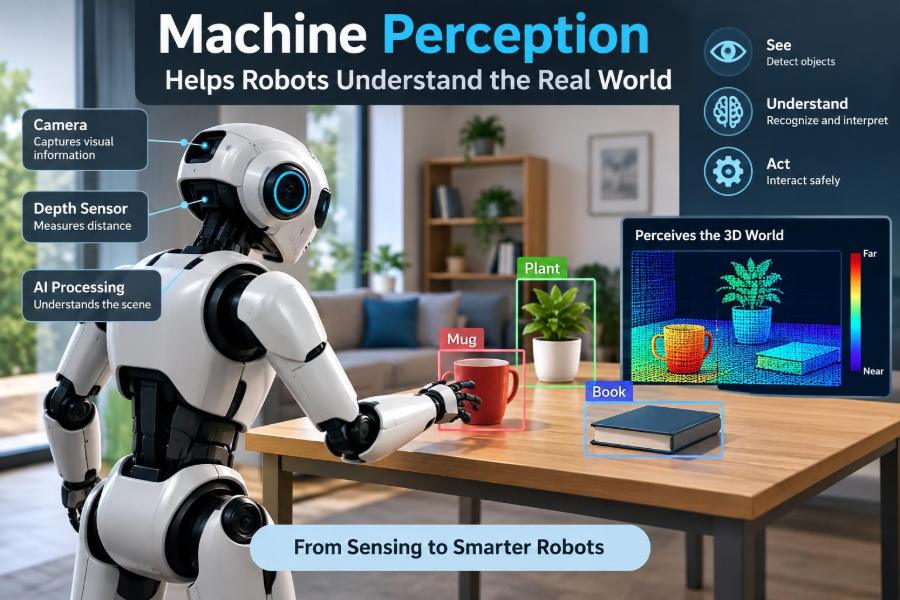
Humanoid robots are becoming increasingly competent in perception of their surroundings and in providing intelligent responses to worldly events. A popular paradigm to realize such responses is the idea of attention itself. There are two important aspects of attention in the context of humanoid robots. First, perception describes how to design the sensory system to filter out useful salient features in the sensory field and perform subsequent higher level processing to perform tasks such as face recognition. Second, the behavioral response defines how the humanoid should act when it encounters the salient features. A model of attention enables the humanoid to achieve a semblance of liveliness that goes beyond exhibiting a mechanized repertoire of responses. It also facilitates progress in realizing models of higher-level cognitive processes such as having people direct the robot’s attention to a specific target stimulus(Cynthia et al., 2001). Studies indicate that humans …
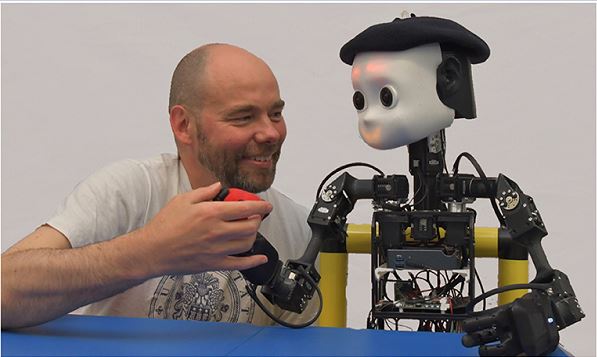
Interaction Through Cognitive Architecture Development of humanoid robots has to address two vital aspects, namely physical appearance and gestures, that will allow the machines to closely resemble humans. Other aspects such as "social" and "emotional" will enable human-machine interaction to be as natural as possible. The field of robotics has long been investigating how effective interaction between humans and autonomous and intelligent mechanical system can be possible (Goodrich & Schultz., 2007). Several distinctive features have been determined depending on whether a robot that acts as an assistant (for example, in the course of a business) or as a companion is …
There have been many researches of robot hands in robot fields and they have been considered one of the most complicated area. There are many reasons why researches of robotic hand are difficult, and these are from complicated structures and functions of hands. There are many types of robotic hands in robotics area, but they can be classified to major…