Skip to content
  • facebook.com
  • twitter.com
  • t.me
  • instagram.com
  • youtube.com
Robotics Engineering

Engineering Intelligence. Creating the Future of Automation.

Subscribe
  • Online Tools
  • Home
  • Robotics Engineering App
  • Home
  • pose estimation
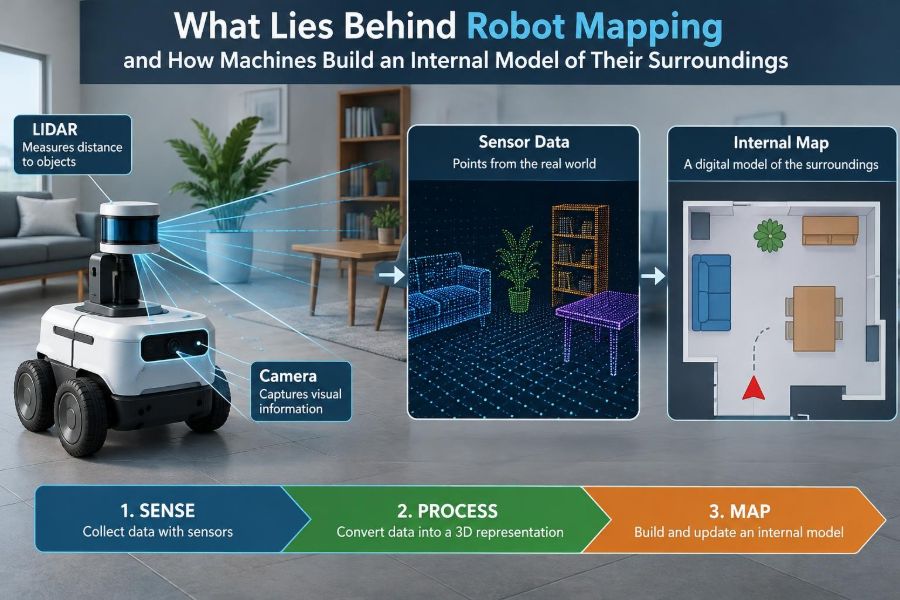
🦾 What Lies Behind Robot Mapping and How Machines Build an Internal Model of Their Surroundings
Posted inFeatured

🦾 What Lies Behind Robot Mapping and How Machines Build an Internal Model of Their Surroundings

Posted by admin November 20, 2026
From lidar scans to loop closure, see how robots turn uncertain sensor readings into usable maps—and why a small error can change every navigation decision. 📡🤖🧭
Read More

Recent Posts

  • 🦾 Exploring Force-Torque Sensors: How Robots Learn to Handle Objects More Delicately
  • 🦾 What Lies Behind Robot Mapping and How Machines Build an Internal Model of Their Surroundings
  • 🦾 Who Teaches Industrial Robots What to Do—and How Are Their Tasks Programmed?
  • 🦾 The Evolution of Robot Grippers: From Simple Claws to Adaptive and Soft Robotic Hands
  • 🦾 Why Is Feedback Control So Important for Precise Robot Movement?

Recent Comments

No comments to show.

Archives

  • November 2026
  • October 2026
  • September 2026
  • August 2026
  • March 2025
  • February 2025
  • October 2024
  • January 2022
  • November 2021
  • October 2021
  • August 2021
  • September 2020

Categories

  • Autonomous Vehicles
  • Basics
  • Featured
  • Humanoid Application and Research
  • Kinematics
  • Motion Tracking and Gesture Recognition
  • New Trends in 3D Printing
  • Recent Advances in Robotic Systems
  • Robot Building
  • Robot Programming
  • Robotic Kits
  • Robotic System Application Control and Progress
  • Robotics Operation in Hazardous Environment
  • Search and Rescue Robots
Copyright 2026 — Robotics Engineering. All rights reserved. Bloghash WordPress Theme
Scroll to Top