Skip to content
  • facebook.com
  • twitter.com
  • t.me
  • instagram.com
  • youtube.com
Robotics Engineering

Engineering Intelligence. Creating the Future of Automation.

Subscribe
  • Online Tools
  • Home
  • Robotics Engineering App
  • Home
  • dynamic environments
🦾 Overcoming Robot Localization Errors in Dynamic Environments
Posted inFeatured

🦾 Overcoming Robot Localization Errors in Dynamic Environments

Posted by admin October 19, 2026
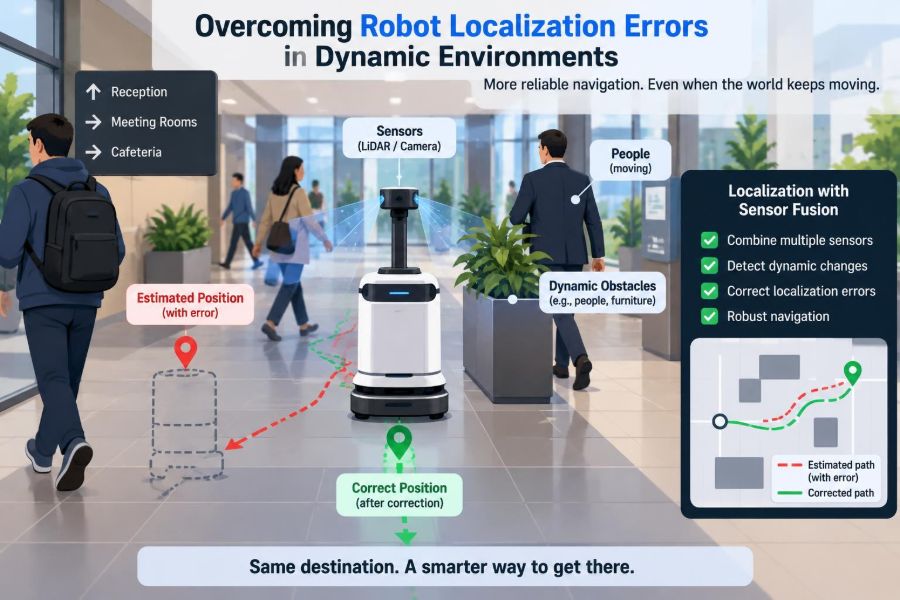
Moving people, shifted pallets, glare, and wheel slip can quietly derail robot localization. Learn how robust sensing, uncertainty, and recovery logic keep navigation dependable. 📡🗺️⚙️
Read More

Recent Posts

  • 🦾 Overcoming Robot Localization Errors in Dynamic Environments
  • 🦾 Expectation vs Reality: How Capable Are Humanoid Robots Outside Controlled Demonstrations?
  • 🦾 How Manufacturers Build Industrial Robots for Speed, Precision, and Repetitive Work
  • 🦾 Reasons Why Robots Become Less Accurate After Thousands of Operating Cycles
  • 🦾 Applications of Sensor Fusion in Robot Navigation, Mapping, and Autonomous Control

Recent Comments

No comments to show.

Archives

  • October 2026
  • September 2026
  • August 2026
  • March 2025
  • February 2025
  • October 2024
  • January 2022
  • November 2021
  • October 2021
  • August 2021
  • September 2020

Categories

  • Autonomous Vehicles
  • Basics
  • Featured
  • Humanoid Application and Research
  • Kinematics
  • Motion Tracking and Gesture Recognition
  • New Trends in 3D Printing
  • Recent Advances in Robotic Systems
  • Robot Building
  • Robot Programming
  • Robotic Kits
  • Robotic System Application Control and Progress
  • Robotics Operation in Hazardous Environment
  • Search and Rescue Robots
Copyright 2026 — Robotics Engineering. All rights reserved. Bloghash WordPress Theme
Scroll to Top