Skip to content
  • facebook.com
  • twitter.com
  • t.me
  • instagram.com
  • youtube.com
Robotics Engineering

Engineering Intelligence. Creating the Future of Automation.

Subscribe
  • Online Tools
  • Home
  • Robotics Engineering App
  • Home
  • Cartesian motion
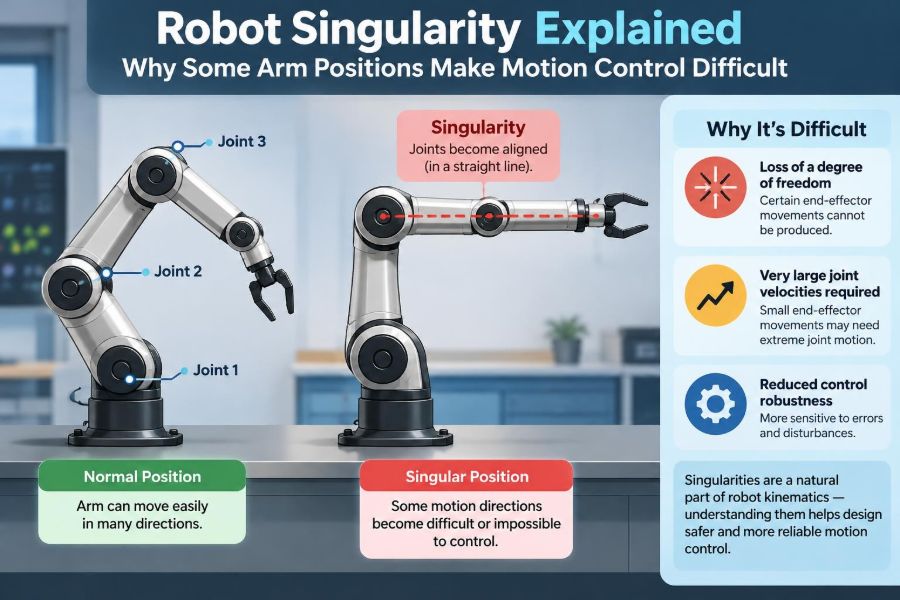
🦾 Robot Singularity Explained: Why Some Arm Positions Make Motion Control Difficult
Posted inFeatured

🦾 Robot Singularity Explained: Why Some Arm Positions Make Motion Control Difficult

Posted by admin November 22, 2026
A pose can be reachable yet still force extreme joint speeds or unstable wrist motion. Learn what robot singularities are and how smarter paths avoid them. 📐⚙️🦾
Read More

Recent Posts

  • 🦾 Robot Singularity Explained: Why Some Arm Positions Make Motion Control Difficult
  • 🦾 Exploring Force-Torque Sensors: How Robots Learn to Handle Objects More Delicately
  • 🦾 What Lies Behind Robot Mapping and How Machines Build an Internal Model of Their Surroundings
  • 🦾 Who Teaches Industrial Robots What to Do—and How Are Their Tasks Programmed?
  • 🦾 The Evolution of Robot Grippers: From Simple Claws to Adaptive and Soft Robotic Hands

Recent Comments

No comments to show.

Archives

  • November 2026
  • October 2026
  • September 2026
  • August 2026
  • March 2025
  • February 2025
  • October 2024
  • January 2022
  • November 2021
  • October 2021
  • August 2021
  • September 2020

Categories

  • Autonomous Vehicles
  • Basics
  • Featured
  • Humanoid Application and Research
  • Kinematics
  • Motion Tracking and Gesture Recognition
  • New Trends in 3D Printing
  • Recent Advances in Robotic Systems
  • Robot Building
  • Robot Programming
  • Robotic Kits
  • Robotic System Application Control and Progress
  • Robotics Operation in Hazardous Environment
  • Search and Rescue Robots
Copyright 2026 — Robotics Engineering. All rights reserved. Bloghash WordPress Theme
Scroll to Top