Posted inBasics Dynamics Posted by admin August 11, 2021 In this chapter, we analyze the dynamic behavior of robot mechanisms. The dynamic behavior is…
Posted inBasics Duality of Differential Kinematics and Statics Posted by admin August 11, 2021 We have found that the equivalent joint torques are related to the endpoint force by…
Posted inBasics Statics Posted by admin August 11, 2021 Robots physically interact with the environment through mechanical contacts. Mating work pieces in a robotic…
Posted inBasics Inverse Kinematics of Differential Motion Posted by admin August 11, 2021 Now that we know the basic properties of the Jacobian, we are ready to formulate…
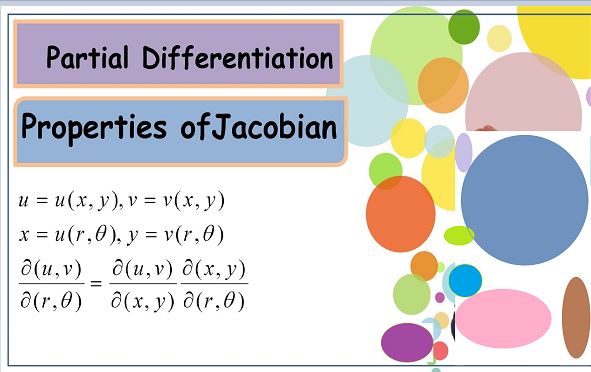
Posted inBasics Properties of the Jacobian Posted by admin August 11, 2021 The Jacobian plays an important role in the analysis, design, and control of robotic systems.…
Posted inBasics Differential Motion Posted by admin August 11, 2021 In the previous chapter, the position and orientation of the manipulator end-effecter were evaluated in…
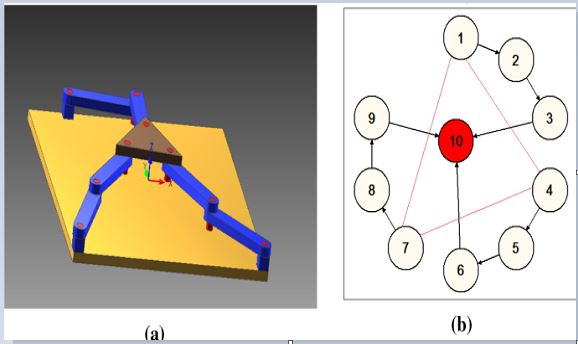
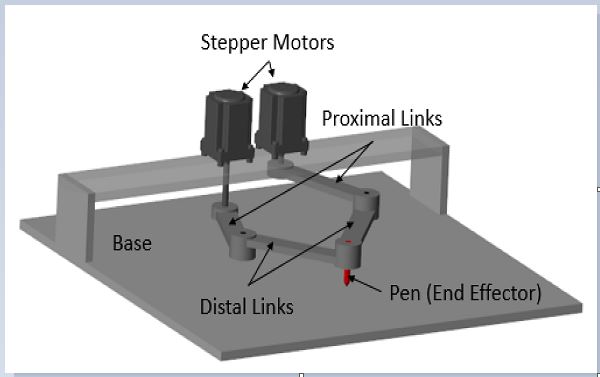
Posted inBasics Kinematics of Parallel Link Mechanisms Posted by admin August 11, 2021 Consider the five-bar-link planar robot arm Note that Joint 2 is a passive joint. Hence,…
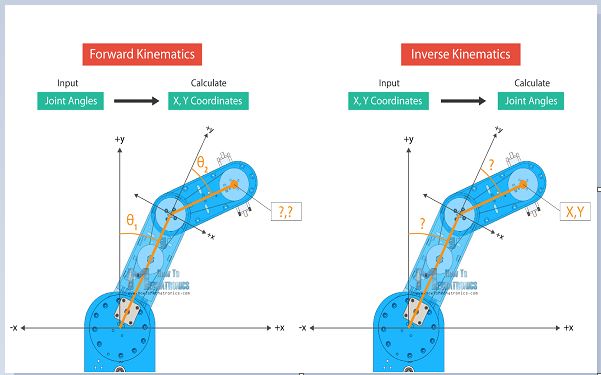
Posted inBasics Inverse Kinematics of Planar Mechanisms Posted by admin August 11, 2021 The vector kinematic equation derived in the previous section provides the functional relationship between the…
Posted inBasics Planar Kinematics Posted by admin August 11, 2021 Kinematics is Geometry of Motion. It is one of the most fundamental disciplines in robotics,…
Posted inBasics Parallel Linkages Posted by admin August 11, 2021 Primitive joints can be arranged in parallel as well as in series. Figure 3.2.1 illustrates…